Physicl Lands $10M to Build Realistic Digital Worlds for Smarter Robots
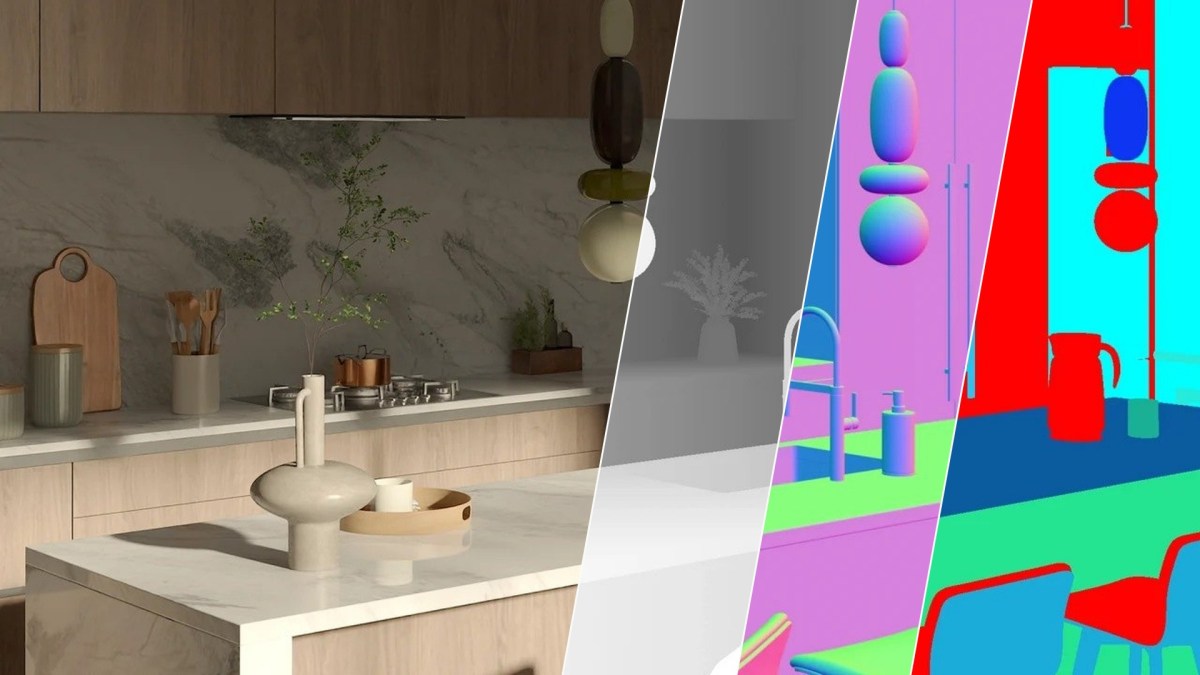
Physicl has secured 10 million dollars in seed funding to develop high-fidelity simulations that help robots learn real-world tasks more effectively.
The company builds on technology from its founder Alex de Vigan's prior work in 3D product modeling for e-commerce.
How Better Simulations Speed Up Robot Adoption
Realistic digital environments allow robot developers to test edge cases like cluttered surfaces or poor lighting without expensive physical setups.
This approach reduces reliance on video data or remote human operation, which often falls short for complex manipulation skills.
Founders in robotics can now generate synthetic training data on demand, cutting development cycles from months to weeks.
Small teams without access to massive data collection resources stand to gain the most from such tools.
12-Month Outlook and Industry Ripple Effects
Over the next year, wider use of these simulations could accelerate robot deployment in warehouses and homes by improving model accuracy on rare scenarios.
Historical patterns show simulation tech first boosted self-driving cars and video games before expanding to physical AI applications.
One early user, SpAItial, already leveraged the platform to refine its world models for better 3D generation from images.
Physicl positions itself as ongoing tooling rather than a one-time data supplier, enabling automated data creation tied to model training needs.
Broader adoption may shift power toward simulation specialists while pressuring traditional data labeling firms.